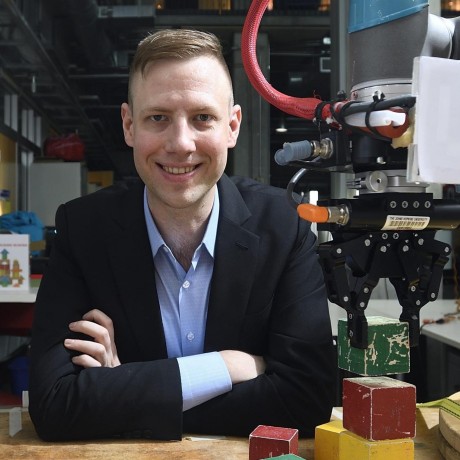
Andrew Hundt
Computing Innovation Postdoctoral Fellow
Pittsburgh, Pennsylvania, United States


Summary
🤩
Rockstar🎓
Top SchoolAndrew Hundt is a Computing Innovation Postdoctoral Fellow and robotics-focused software engineer with 13 years of hands-on experience building integrated learning and traditional algorithms for real-world agents. He combines deep-learning expertise (PyTorch, TensorFlow, Keras) and robotics/vision systems with low-level engineering in C/C++, CAD and build systems to enable smoother robot calibration, perception, and control. His work spans academia and industry—from a PhD at Johns Hopkins and postdocs at CMU and Georgia Tech to a confidential robotics “moonshot” at X—and includes sustained open-source contributions to widely used projects like Keras, Bullet Physics, and hand-eye calibration tools. Known for improving runtime and robustness (e.g., TensorFlow grasping pipelines and reliable hand-eye calibration for UR5/Kuka systems), he also brings strong DevOps, documentation, and mentoring skills that bridge research prototypes to production-grade systems.
 14 years of coding experience
 5 years of employment as a software developer
 Johns Hopkins UniversityBS, BS at Carnegie Mellon University

Stackoverflow
2,601reputation
225kreached
20answers
41questions

Github Skills (47)
c-language10
robotics10
multiplatform10
python10
data-science10
sphinx10
data-set10
semantic-segmentation10
machine-learning10
build-system10
cmake10
cross-platform10
datasets10
keras10
deep-learning10
Programming languages (21)
Github contributions (5)
keras-team/keras-contrib
Mar 2017 - Oct 2018
Keras community contributions
Role in this project: Backend Developer
Contributions:114 commits, 117 PRs, 59 pushes in 1 year 6 months
Contributions summary:Andrew contributed to the `keras-contrib` repository by implementing support for the MSCOCO dataset and Pascal VOC 2012 dataset. They also made improvements to various dataset-related files. Furthermore, the user addressed runtime errors and ensured PEP8 compliance within the codebase, demonstrating a focus on code quality and dataset integration. The contributions suggest a focus on data handling and integration within the context of a deep learning library.
kerastheanotensorflowmachine-learningdeep-learning
jhu-lcsr/handeye_calib_camodocal
Apr 2016 - Apr 2018
Easy to use and accurate hand eye calibration which has been working reliably for years (2016-present) with kinect, kinectv2, rgbd cameras, optical trackers, and several robots including the ur5 and kuka iiwa.
Role in this project:Back-end Developer
Back-end DeveloperContributions:36 commits, 11 PRs, 32 pushes in 2 years
Contributions summary:Andrew primarily worked on the hand-eye calibration code, adding debugging outputs and preparing for saving transforms to a file. They integrated code from a master branch, fixing quaternion printouts and addressing uninitialized variable issues. Their contributions include implementing features related to transformation handling and calibration results, likely focusing on improving the accuracy and usability of the hand-eye calibration process. The user demonstrated skills in C++ and interaction with libraries like Eigen and camodocal.
kinectkinect-v2hand-eye-calibrationrosrobot-arm
Find and Hire Top DevelopersWe’ve analyzed the programming source code of over 60 million software developers on GitHub and scored them by 50,000 skills. Sign-up on Prog,AI to search for software developers.